Industrial manipulators
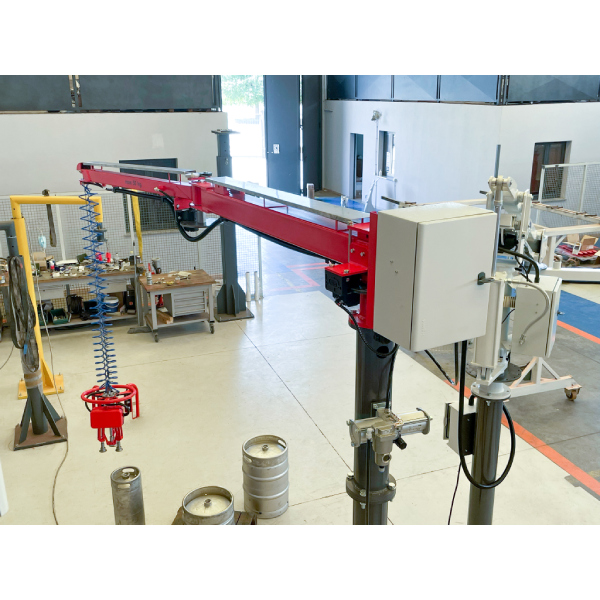
The full range of manipulators from our offer are manual handling devices. Industrial manipulators can be divided into pneumatic and link.
Each manipulator is designed for individual customer needs. Thanks to this, the device works with machines and/or supports all those that are already on site and fits perfectly into the company’s characteristics.
- MAXIMUM LAMP – 5 000 mm
- MINIMUM DRIVERS – 800 mm
- VERTICAL DEFLECTION – 1 600 – 2 000 mm
- SEVENTH – 50 – 1 500 kg
- PRESSURE – 8 bar
The pneumatic industrial manipulators are primarily:
- no electrical cables,
- no risks to the operator,
- Resistance to explosive chemical or other hazardous environments.
Application
The primary use of manipulators is the multiple, repetitive transfer and deposition of cargo in every possible sector.
- material cutting work ( saw, laser),
- machining work (CNC, lathes, milling machines, drilling machines, hydraulic presses),
- assembly of pre-worked parts,
- packaging processes,
- loading and unloading,
- installation and maintenance works.
All for production and assembly lines
- operator and cargo safety,
- minor changes within the workplace,
- the autonomy of the employee,
- simple maintenance,
- ergonomic work,
- intuitive operation,
- reduced risk of injuries and accidents.
Different kinds of grippers
The grasping tool is made under strict customer design:
- standard hooks,
- hooks or forks of a special shape,
- hand-operated mechanical grippers,
- pneumatic-controlled mechanical grippers,
- vacuum grippers,
- magnetic type grippers.
Construction
The adaption of the manipulator depends on the type of work done and the conditions in the workplace.
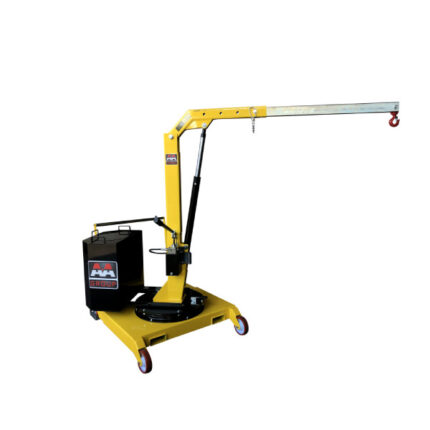
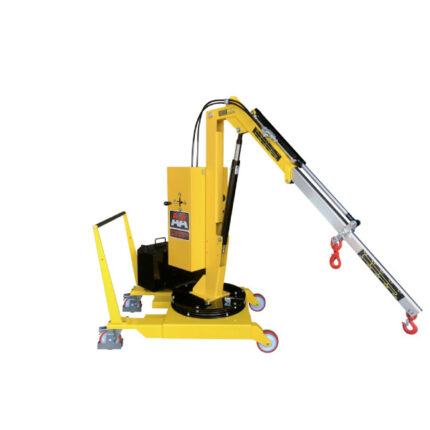
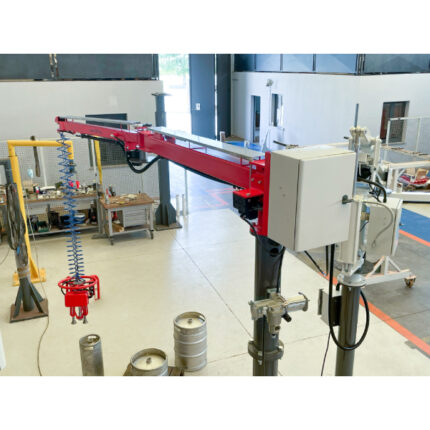
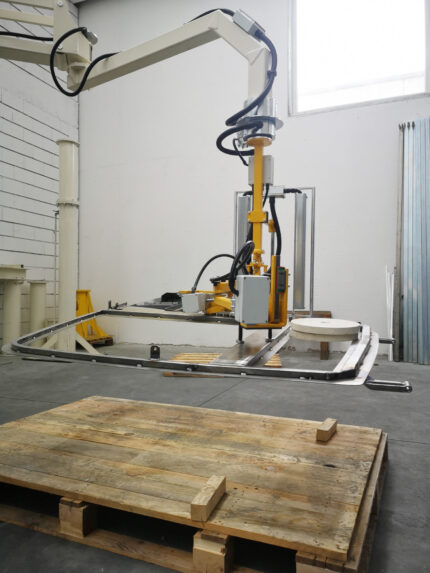
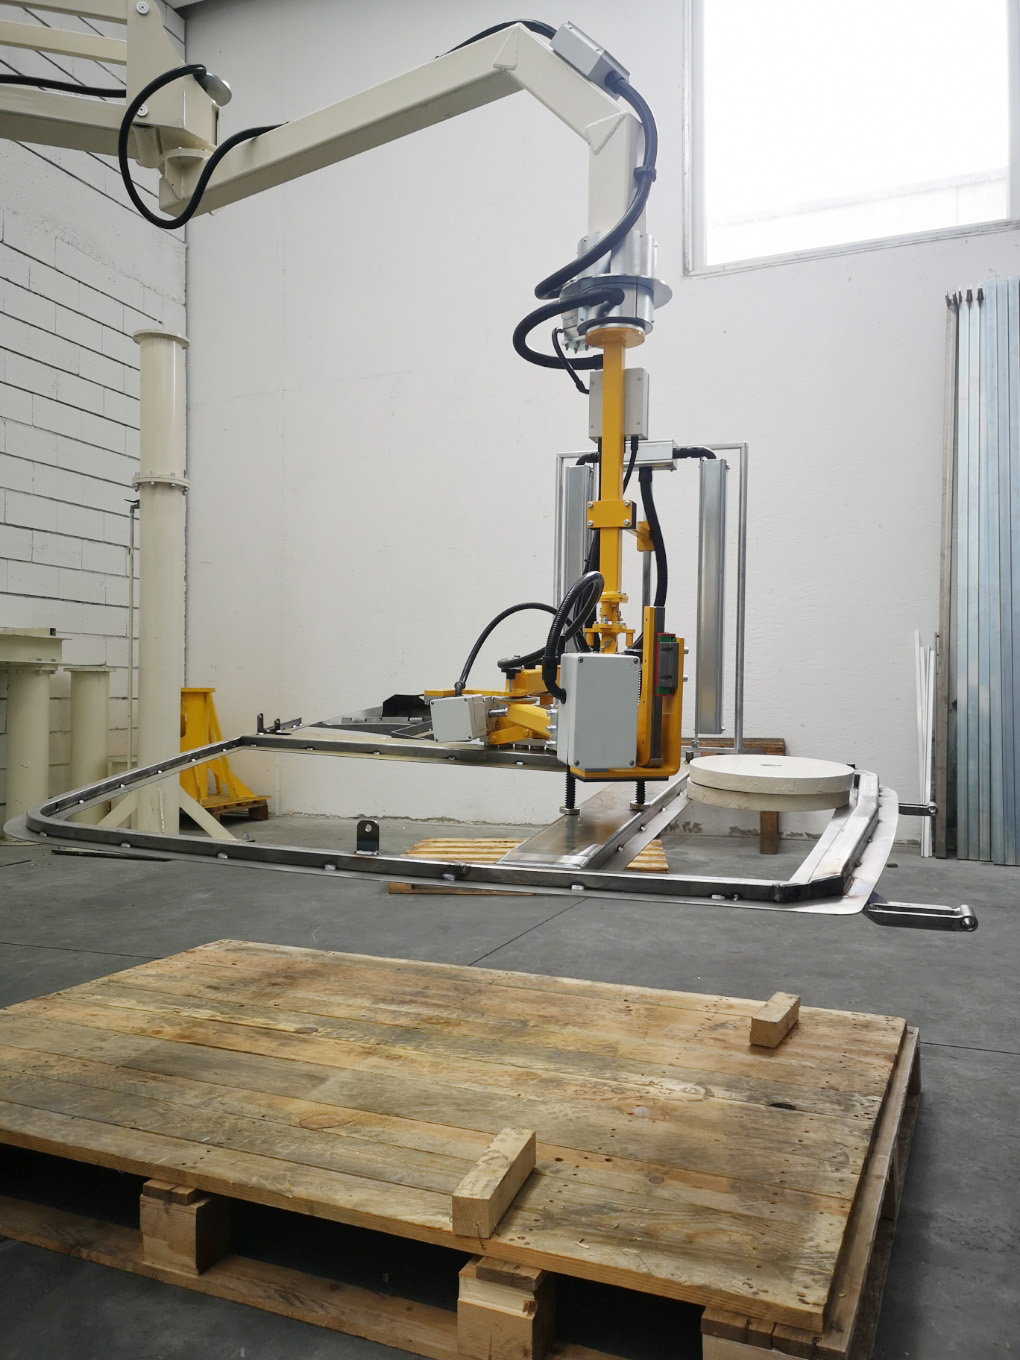
When we have to keep the charge out of the middle or when we need to make a tilt and/or turn, we usually use a manipulator with a rigid arm. This arm can be set on a column on the floor, hung on a flange fixing from above or connected to a suspended trolley system on a simple track to move the manipulator on a large surface.
The unique design of the manipulator allows objects to move in each direction within the radius determined by the length of the arm. The area of operation of the manipulator in 3D space is a roller whose height is the height of the pole, and the radius is determined by the length of the arm.
IMPORTANT: It is important to specify exactly what the manipulator is meant to do. For example, a device that is designed to carry 200 kg and then serves to carry loads up to 80 kg is made disproportionately and will be difficult to control and maneuver. Due to its more massive design, the manipulator will not work fast enough in this case.
Industrial manipulators